Originally published on EmbeddedRelated.
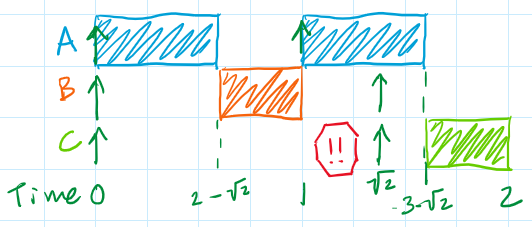
Part 2 of the “You Don’t Need an RTOS” series takes the simple superloop from Part 1 and applies three targeted modifications that together produce what I call the “Superduperloop”: a non-preemptive scheduler whose worst-case response time approaches that of a preemptive RTOS. The three changes are adding task priorities (via if/else-if chains so higher-priority tasks preempt lower ones at loop boundaries), adding interrupt service routines for truly time-critical work, and restructuring tasks as finite state machines so long-running operations yield voluntarily without blocking the scheduler. Three different methods for assigning task priorities are discussed and demonstrated.
A concrete benchmark shows the Superduperloop besting a preemptive RTOS on worst-case response time in a specific task set, by exploiting the determinism of non-preemptive scheduling. The article also covers how to incorporate a sleep mode when there is no work to be done, and introduces the time-triggered scheduler as an alternative design for difficult task sets.
Additional Resources
- You Don’t Need an RTOS (Teardown 2025) — a talk covering the schedulability analysis and the case for cooperative scheduling